
Robotic manipulators that work safely and efficiently alongside people.
Dynamium is the Dynamic Systems Laboratory at Université de Moncton. We study the motion planning, dynamics and control of robotic manipulators, with a focus on collaborative robots and physical human-robot interaction.
Research areas
Our work combines modelling, optimization and experiments on collaborative robots from Kinova and Universal Robots.
Trajectory optimization and motion planning
Time-optimal trajectories for serial manipulators, including redundant arms, payload limits and collision avoidance.
Physical human-robot interaction
Collaborative robots that share a workspace and tasks with people, including dynamic identification of the robot and its payload.
Kinematics and dynamics of parallel manipulators
Synthesis and analysis of parallel manipulator architectures, including kinematic redundancy.
Ergonomics and biomechanics
Upper-limb movement and musculoskeletal disorders, to design safer workstations and human-robot tasks.
Members
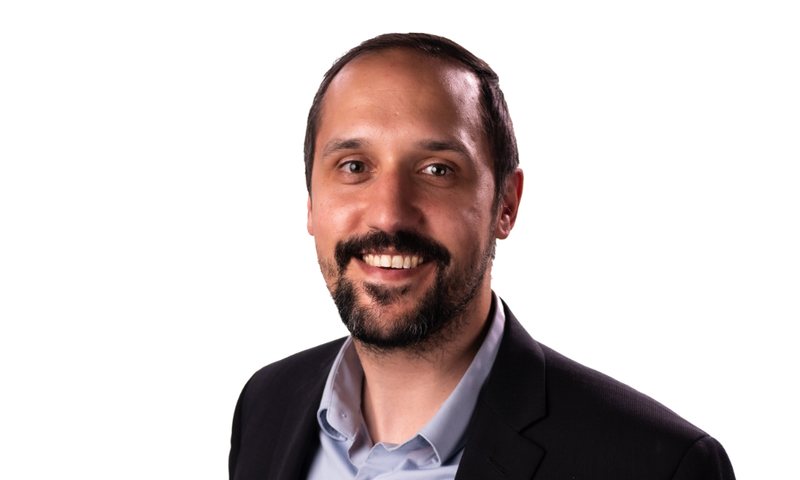
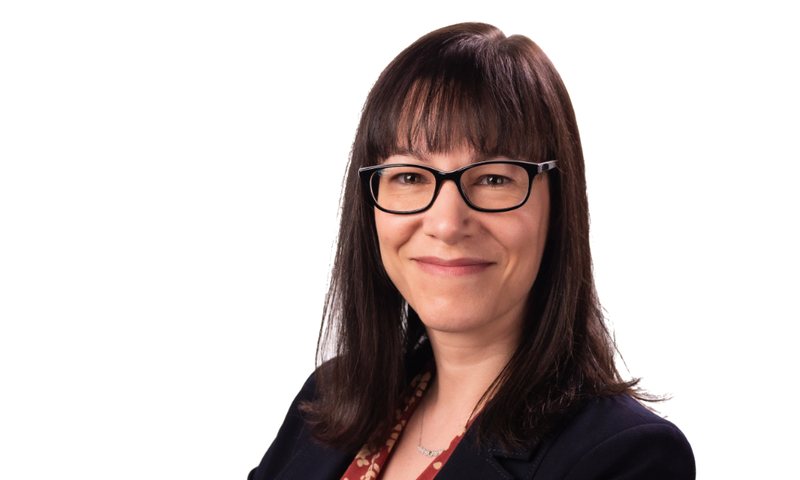
Professors
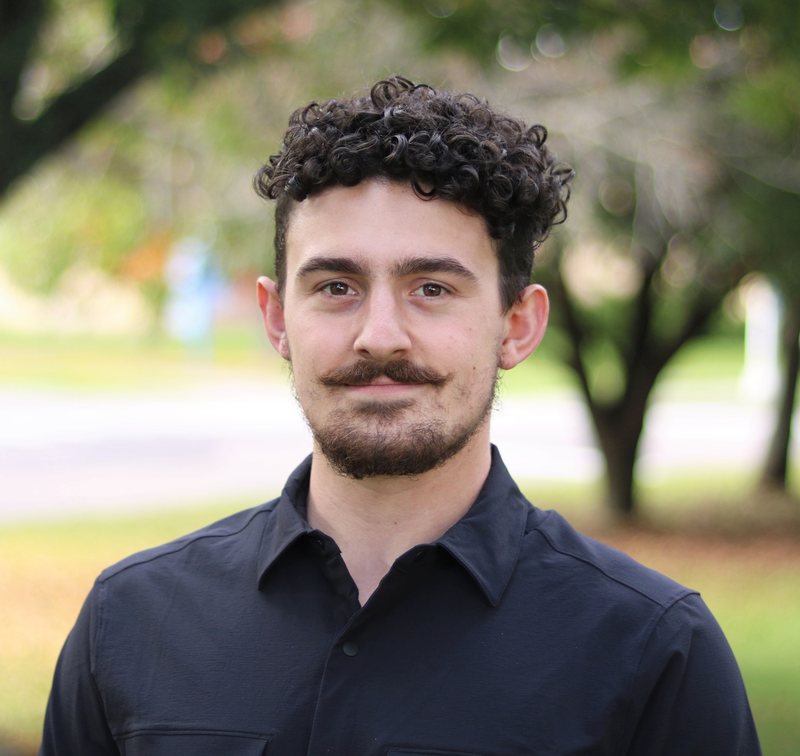
Research staff and graduate students

Alumni
- Mouad Chabba
MScA, 2026 - Meriem Haddaji Mastouri
MScA, 2026 - Mouna Elamari
MScA, 2026 - Rafael Arriaga Hernández
Research Intern, 2025 - Natanaël Jamet
Mechatronics Engineering Student - Wissem Chiha
Mechanical Engineering Student - Moemen Smiri
Electrical Engineering Student - Vaibhav Satija
BEng, Software Engineering - Antonin Ansion
BEng, Mechanical Engineering - Joshua Flight
BEng, Mechanical Engineering
Contact
We welcome research collaborations with industrial partners and academic colleagues. Prospective graduate students should write directly to the professor whose research matches their interests.
Dynamium, Dynamic Systems LaboratoryDepartment of Mechanical Engineering
Faculty of Engineering
Université de Moncton
18 Antonine-Maillet Avenue
Moncton, New Brunswick E1A 3E9, Canada